Physical AI Systems
Volume IV of Machine Learning Systems: Physical AI Systems. Foundations for machines where learned models act in the physical world under real-time constraints and physical laws.
This is an active draft. Physical AI systems begin where computation stops being symbolic and becomes physical force. Once an algorithm commands a motor, the forgiving conventions of digital software give way to mechanics, thermodynamics, and actions that cannot be undone.
The volume establishes the systems foundations for machines where learned models act in the physical world under real-time constraints, latency limits, and physical laws.
Welcome
What You Will Learn
The book opens with an introduction, develops its argument in four parts, and closes with a conclusion:
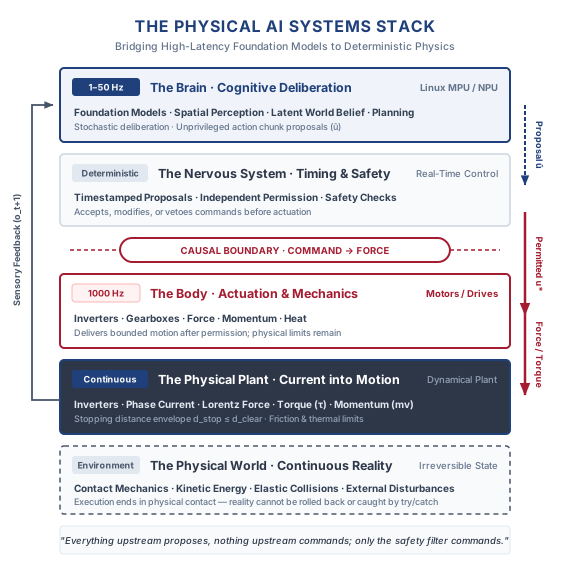
- Introduction defines the causal boundary, where a permitted command becomes current, force, and motion, and orders the machine into the five levels the rest of the book builds on.
- The Machine Anatomy develops the Body, the Brain, and the Nervous System, turning the irreversibility of physical work into budgets of time, distance, torque, heat, and voltage.
- Teaching the Machine develops data, training, and evaluation for systems whose own actions determine what they observe next.
- Running the Machine develops perception, memory, intent, planning, enforcement, and placement across the timescales that separate deliberation from motor control.
- Governing the Machine develops intervention, verification, and release, covering what dependability requires once a machine leaves the laboratory.
- Conclusion returns to what a machine must guarantee before a learned proposal becomes physical work, answers with what the evidence supports, and enters each premise the evidence leaves open in a residual-claims register.